A control stack, already connected.
Ubuntu with PREEMPT_RT and the IgH EtherCAT Master connects the field bus to ROS 2. Start from a configured control platform and focus on application development.
Dual 2.5 GbE. PREEMPT_RT. An integrated EtherCAT control platform for research, education and light automation.
Configuration on request.
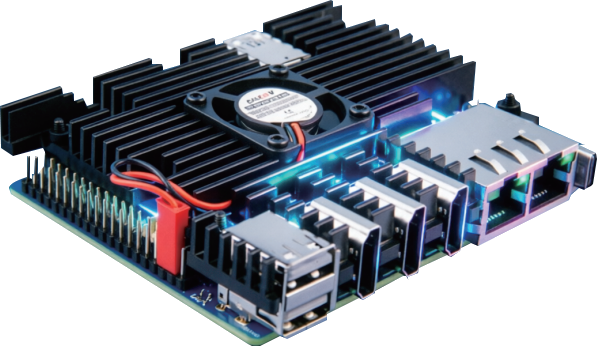
Ubuntu with PREEMPT_RT and the IgH EtherCAT Master connects the field bus to ROS 2. Start from a configured control platform and focus on application development.
RayStudio brings motor parameters, motion programming, recorded trajectories and live monitoring into the browser. Companion guides cover CSP, CSV, CST and MIT control modes.
Jetson Orin NX SUPER 16GB. Up to 157 TOPS. Five independent EtherCAT ports for an integrated robot architecture.
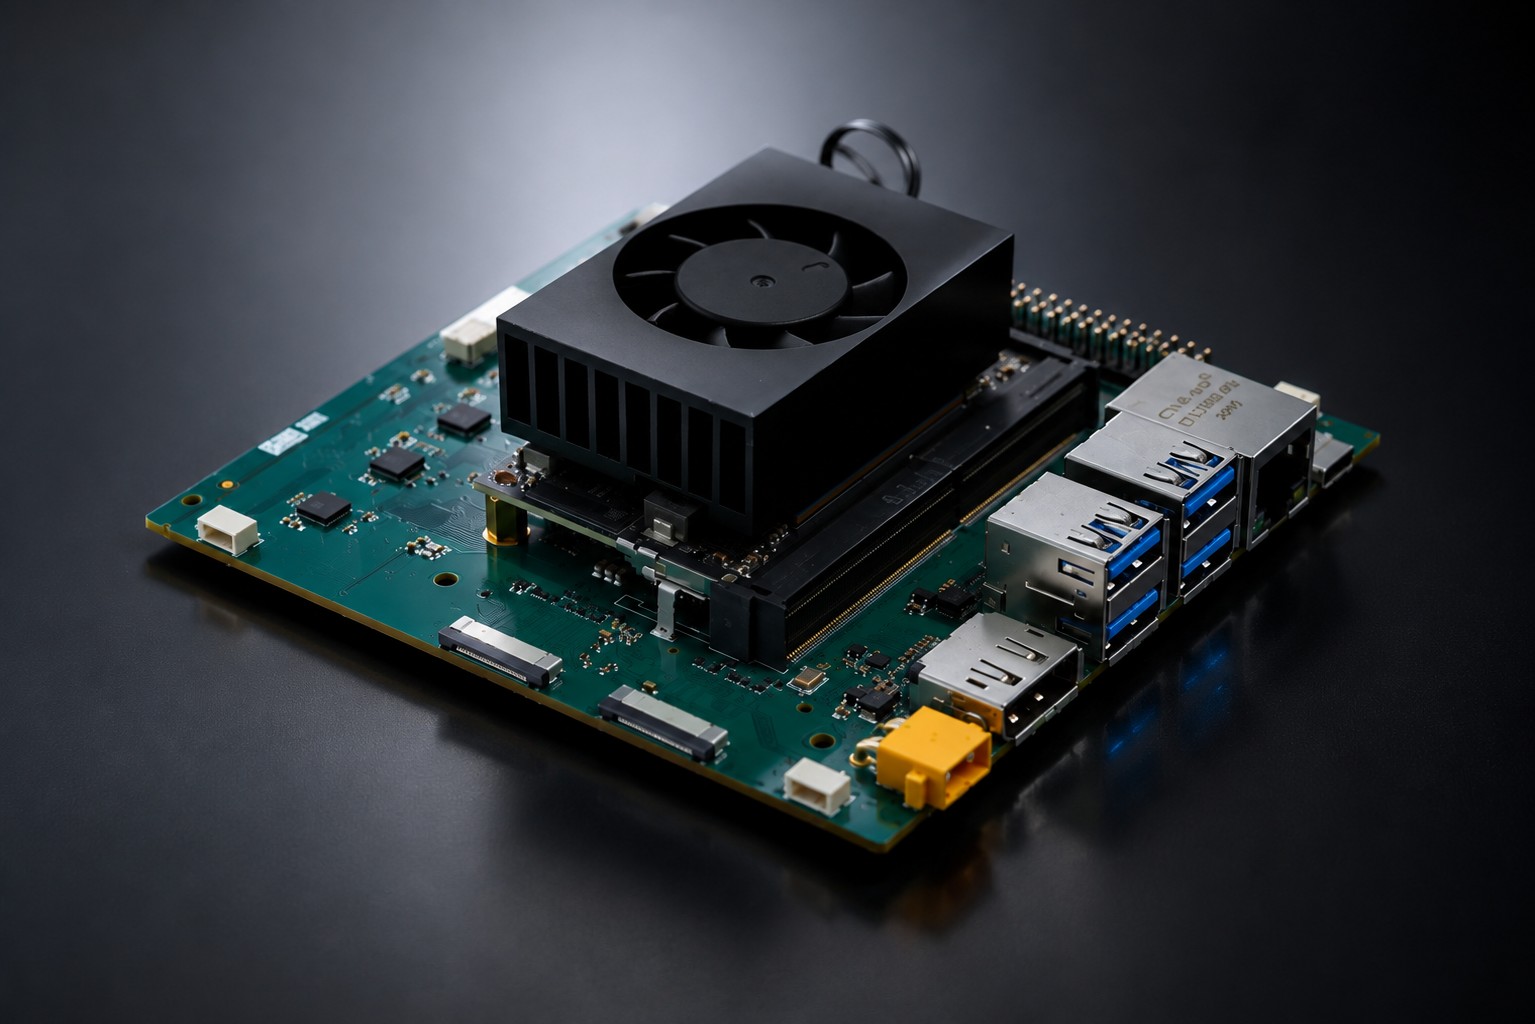 View product
A six-axis desktop arm with a 2 kg payload. Built for teaching, manipulation and embodied AI development.
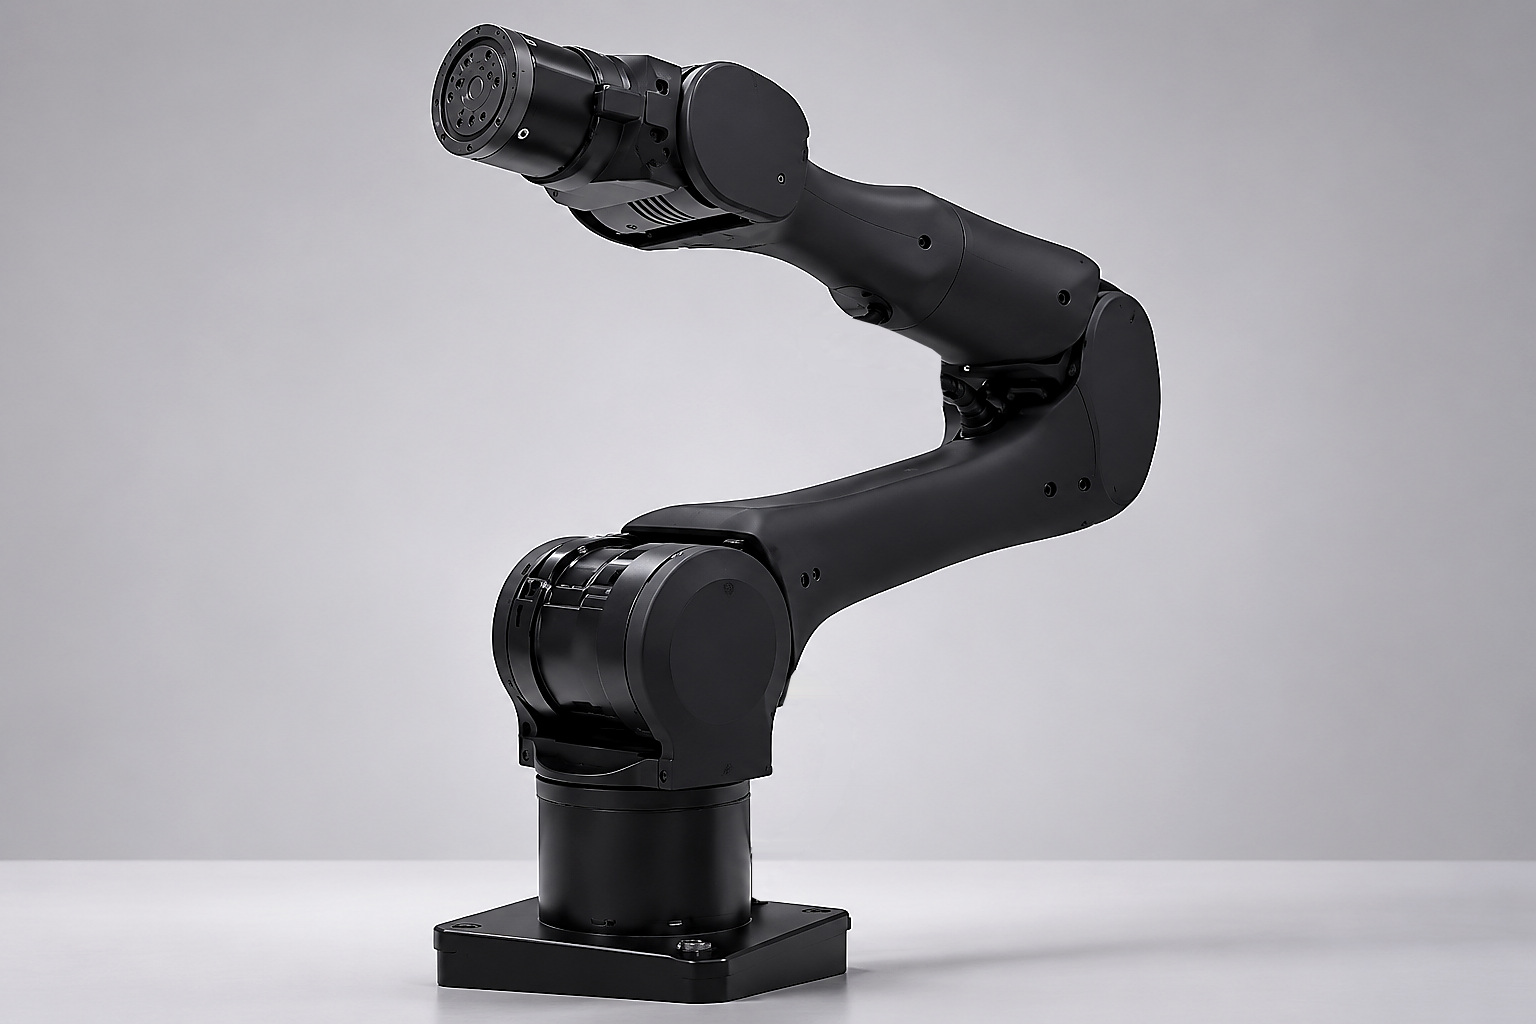 View product
The controller uses an Orange Pi platform with 16 GB RAM, 64 GB storage and dual 2.5 GbE ports.
It is the supported control-frequency ceiling. The achievable rate depends on the device topology, control workload and configuration.
Yes. The platform supports ROS 2 with Python and C++ development interfaces. Consult the integration documentation for setup.
RB-C002 focuses on real-time control with Orange Pi and dual 2.5 GbE. RB-C004 combines Jetson Orin NX SUPER edge AI compute with five independent EtherCAT ports.
Choose the model and quantity on the inquiry page. Raybot will confirm the configuration, pricing and lead time for your application.
Email tangxc@myactuator.com or call +86 17775378663 with your model, firmware version and integration requirements.